Flight Controllers
F4WSE Pro F405 Fixed-Wing Flight Controller
A Pro fixed-wing F405 flight controller intended for ArduPlane/INAV aircraft. It acts as the aircraft’s autopilot, sensor hub, and servo/ESC output controller.
Choose a product for wiring diagrams, setup instructions and firmware.
A Pro fixed-wing F405 flight controller intended for ArduPlane/INAV aircraft. It acts as the aircraft’s autopilot, sensor hub, and servo/ESC output controller.
H7Wlite V2 hardware revision with dual BMI270 IMUs, SPA06-003 barometer, and internal QMC5883P compass. ArduPilot and INAV retain legacy ICM support; Betaflight is BMI270-only.
An ultra-small fixed-wing autopilot board. It is the central controller for a small plane: it reads sensors, runs ArduPilot/INAV-style flight firmware, outputs servo/PWM control, and provides connectors for receiver and HD video equipment.
STM32H743 FPV flight controller with a switchable 9V BEC for the video transmitter or camera.
A compact F405 FPV flight controller for multirotor builds. It runs Betaflight by default and connects the receiver, ESC signal harness, VTX/camera, OSD, buzzer, LEDs, and other FPV peripherals.
A four-in-one ESC for FPV drones. It takes one battery input and independently drives four brushless motors from flight-controller throttle signals.
A 45 A four-in-one AM32 ESC for FPV drones, intended to drive four brushless motors from one compact board.
A two-in-one AM32 ESC that drives two brushless motors from one compact board. It is especially useful for twin-motor fixed-wing aircraft or compact dual-motor builds.
A 75 A single-channel AM32 ESC for one high-current brushless motor. It is useful when each motor needs its own ESC or when a single powerful motor is used.
A compact 75 A single-channel AM32 ESC with an onboard CAN interface. It is designed to drive one high-current brushless motor in fixed-wing aircraft, boats, vehicles, or other builds that use a separate ESC per motor.
AM32 ESC Controller Board with BEC. Refer to the product manual for wiring and operating limits.
A compact single-channel AM32 ESC. It drives one brushless motor, making it useful for single-motor fixed-wing aircraft, compact vehicles, or builds where separate ESC placement is preferred.
A high-end FPV stack bundle pairing the H7D Pro H743 flight controller with the 75 A 4-in-1 ESC.
An FPV stack bundle pairing the F4D flight controller family with a 75 A 4-in-1 ESC.
An advanced FPV stack bundle combining the H7D Pro H743 flight controller with a 45 A 4-in-1 ESC.
A starter FPV stack bundle combining an F405 flight controller with a 45 A 4-in-1 ESC.
F4WSE Pro flight controller paired with an AM32 Dual 40A ESC.
A higher-voltage step-down BEC for converting 2-12S battery voltage into a regulated lower output for onboard electronics.
A compact high-voltage BEC for 2-12S builds, with 5 V output by default and a 12 V jumper option.
A compact high-current BEC for aircraft and other projects that need a selectable regulated supply.
A small step-down power module. It converts a higher battery voltage into a regulated lower voltage for receivers, flight-controller accessories, servos, video equipment, or other onboard electronics.
A small BEC intended to power DJI O4-style digital video equipment from a higher-voltage flight battery.
A remote-mountable three-axis compass module for heading measurement in aircraft, robotics, and navigation projects.
A CAN-bus compass module built around the PNI RM3100 geomagnetic sensor and AP_Periph-style firmware. It gives autopilots cleaner heading data when the main flight controller is affected by current, motors, or magnetic interference, while keeping remote communication on a robust CAN link.
An external I2C current and voltage sensor for flight controllers. It uses an INA226 sensor so ArduPilot/PX4 systems can read battery voltage and current from an external module instead of relying on an onboard analog current sensor.
A high-current power distribution board for FPV drones. It distributes main battery power to ESCs or other power loads while providing a structured central power node.
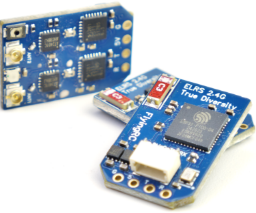
A 2.4 GHz ELRS diversity receiver. It receives control commands from an ExpressLRS transmitter and sends them to the flight controller, using diversity reception for a more robust radio link.
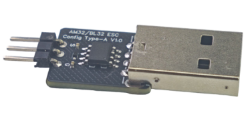
A USB parameter programmer for AM32 ESCs. It bridges the computer tuning software to an ESC signal wire so users can read parameters, change settings, and flash firmware.
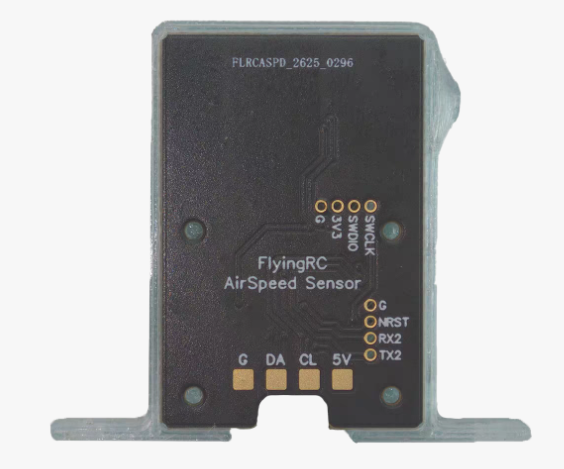
The latest integrated I2C airspeed sensor for fixed-wing aircraft using ArduPilot airspeed workflows.
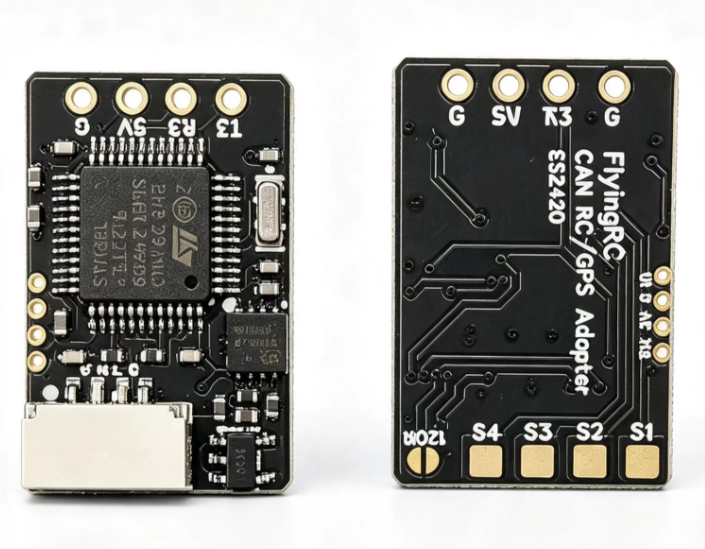
A CAN bus adapter and serial/PWM expansion board. It lets compatible flight controllers add remote serial/PWM-style peripheral connections through an AP_Periph-style CAN node.
A U-Blox M10 GPS module for providing location data to flight controllers, robots, or navigation systems.
An ultra-compact AT32F435 fixed-wing flight controller that combines stabilization, navigation interfaces, servo and ESC outputs, an AT7456F analog OSD, and a digital VTX connector on one board.
A higher-performance fixed-wing flight controller page for users choosing an H7-class board for more processing headroom and richer peripheral integration.
A fixed-wing F405 autopilot board for ArduPilot/INAV-style airplane builds. It sits between receiver/sensors and aircraft servos/ESC, handling stabilization, navigation, telemetry, and flight-mode control.
A high-performance H743 FPV flight controller. It is the main control board for a multirotor: it runs Betaflight/AP/INAV firmware, reads dual gyros and barometer, drives ESC/PWM outputs, and powers/controls VTX and camera accessories.
A GPS/navigation accessory page for FlyingRC CAN/GPS-style products. It provides position data to the flight controller so autonomous modes, return-to-home, navigation, and logging can work.
Learn the difference between VIDEO, CAM, VIN, VOUT, UART TX/RX, SmartAudio, and Tramp to avoid common analog FPV wiring mistakes.
Read tutorialUse ST's official STM32CubeProgrammer to write a FlyingRC .hex firmware file over the STM32 USB bootloader / DFU interface.
Read tutorial