Overview
A CAN-bus compass module built around the PNI RM3100 geomagnetic sensor and AP_Periph-style firmware. It gives autopilots cleaner heading data when the main flight controller is affected by current, motors, or magnetic interference, while keeping remote communication on a robust CAN link.
- RM3100 CAN-bus compass module
- STM32L431RCT6 controller with AP_Periph-style firmware workflow
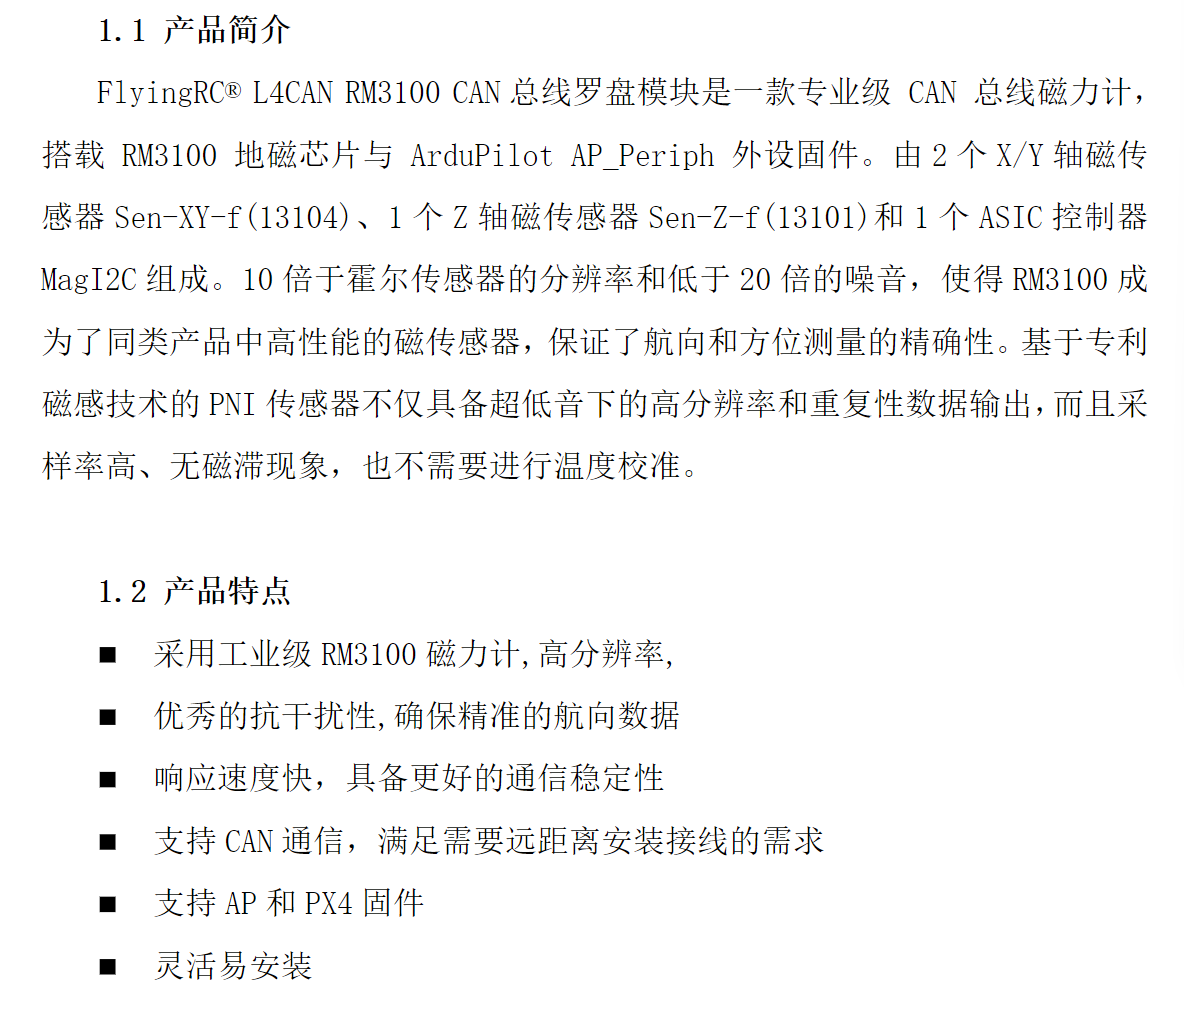
- 29.3 x 29.3 x 9.0 mm board size
Hardware revision
Check the sensor markings and component layout on your board against the manual and diagrams below.
Setup notes
- Mount at least 10 cm away from power wires, ESCs, motors, magnets, and ferrous metal materials.
- If the CAN cable is long, short the onboard 120 ohm termination jumper as needed for the bus layout.
- After installation, configure CAN/AP_Periph parameters and run compass calibration in the flight firmware.
- Size: 29.3 x 29.3 x 9.0 mm.
- Weight: 4.5 g without base, 10.5 g with base.
- Board: 4 layers, 1.64 mm thickness, 1 oz gold-plated finish.
- Controller: STM32L431RCT6.
- RM3100 measurement range: +/-400 uT; sensitivity: 13 nT; noise: 15 nT; maximum tri-axis sampling rate: 550 Hz.
- ArduPilot branch: FlyingRC-Official/ardupilot L4_CAN_RM3100.
- Compass accuracy depends on magnetic cleanliness, orientation, CAN bus wiring, and correct firmware setup.
Wiring, dimensions & photos
Parameter and package list
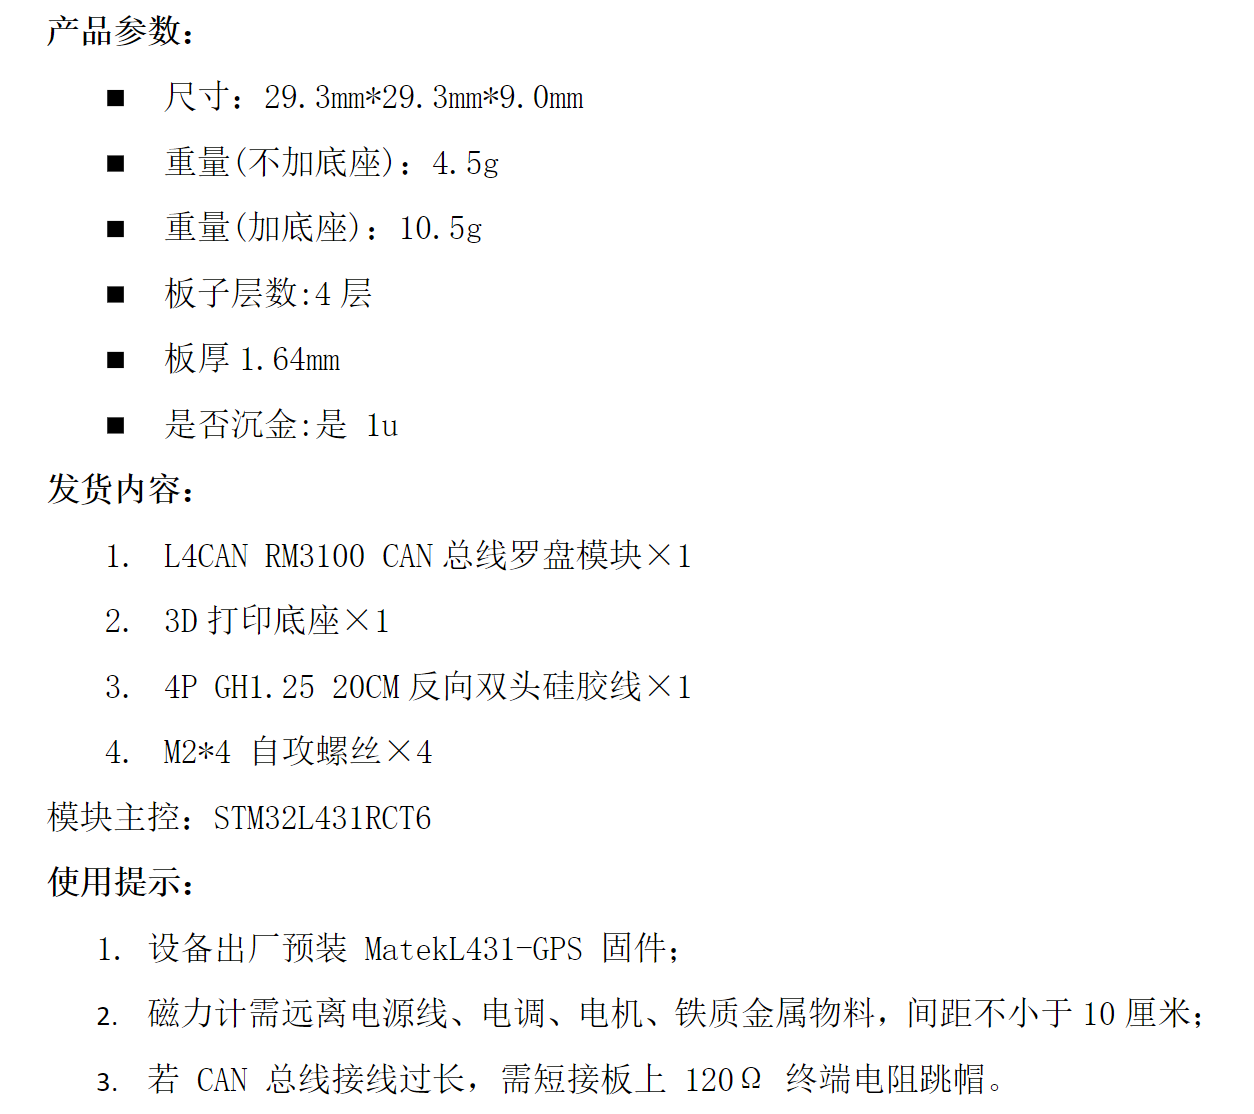
Product introduction
Dimension drawing
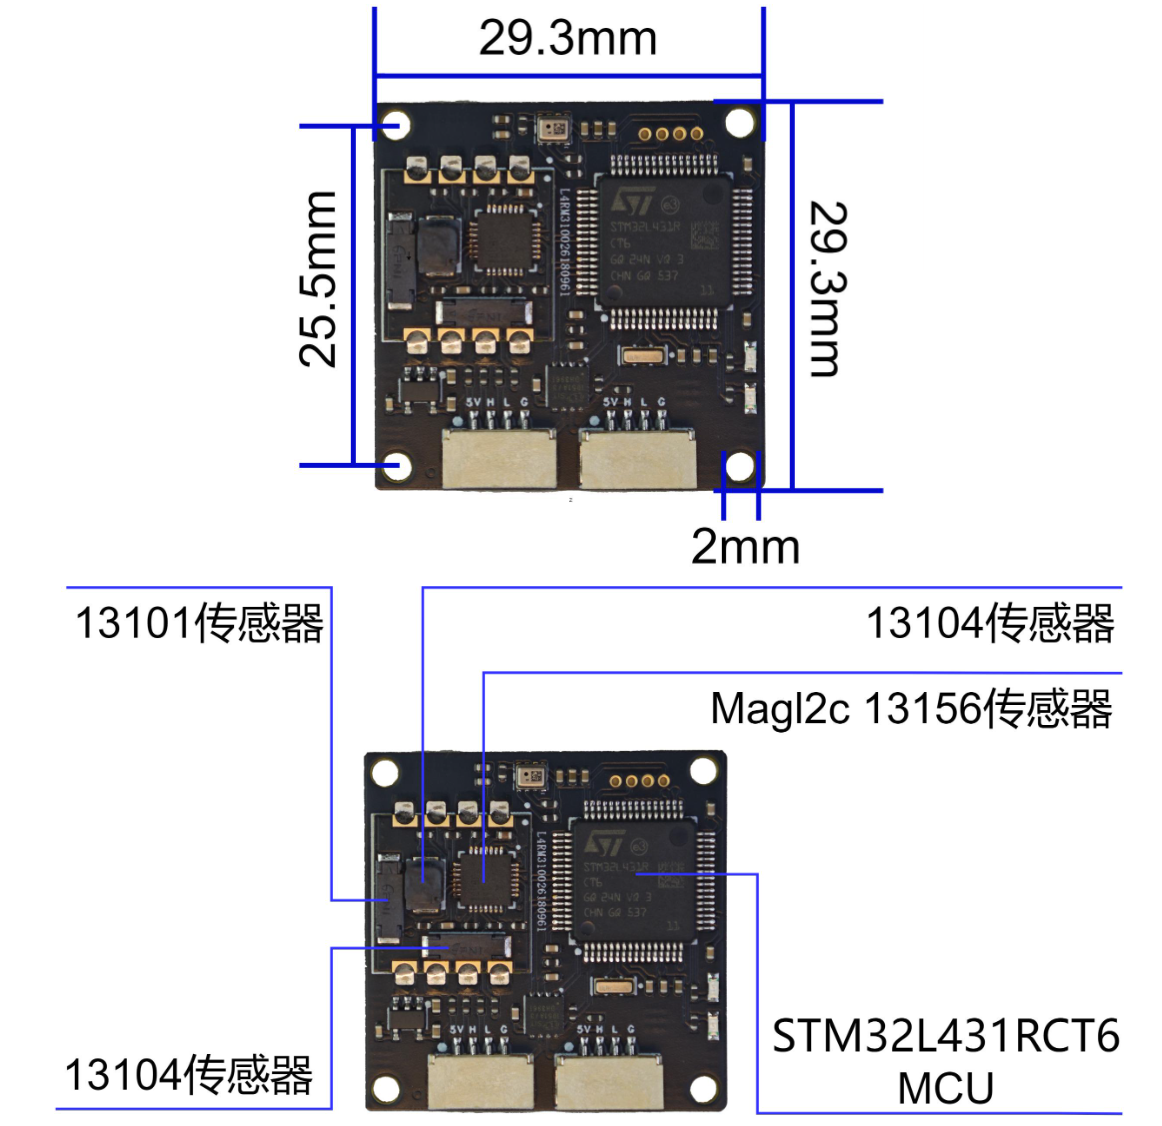
Front 3D render

Front product photo

Back product photo

Package contents

Technical parameter table

H7D Pro wiring

Firmware & manuals
ArduPilot L4 CAN RM3100 branchOpen / download