FlyingRC

How to choose a flight controller

A flight controller must match the aircraft, firmware workflow, required outputs and exact sensor revision.

Choose by aircraft and workload

Fixed-wing builds usually prioritize servo outputs, logging, airspeed or GPS interfaces and ArduPlane or INAV support. FPV multirotors usually prioritize mounting pattern, gyro configuration, ESC connection and video-system power.

Verify the exact revision

The MCU family alone is not enough. Confirm IMU and barometer markings, board revision, connector layout and the firmware target printed in the relevant download entry before flashing.
Relevant FlyingRC hardware

Flight Controllers

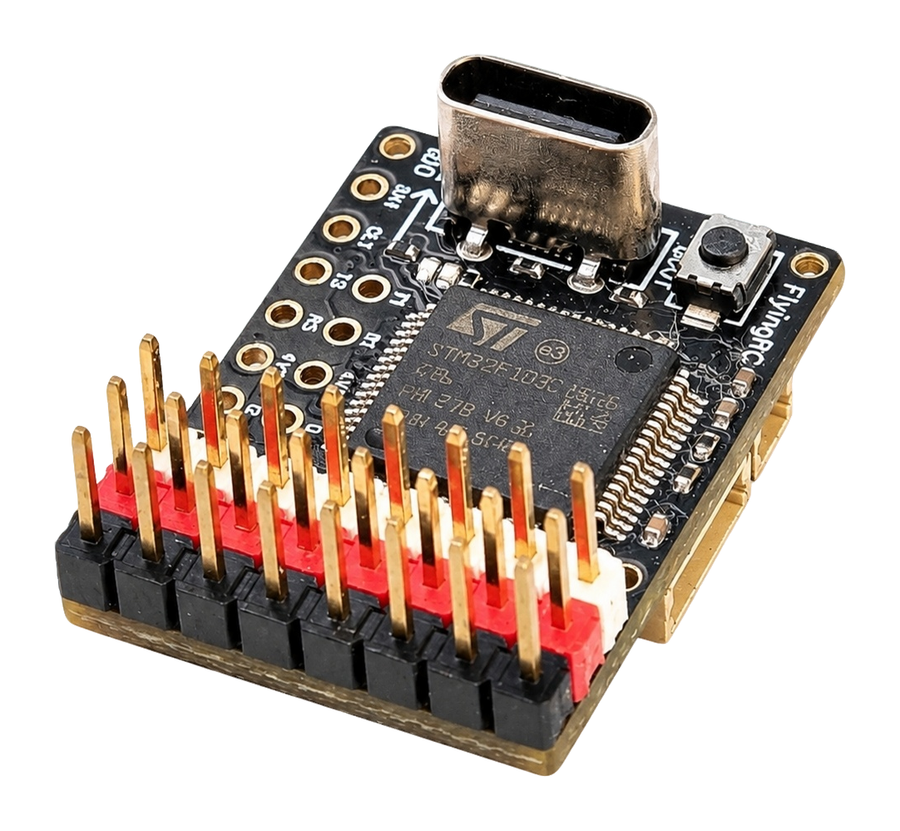
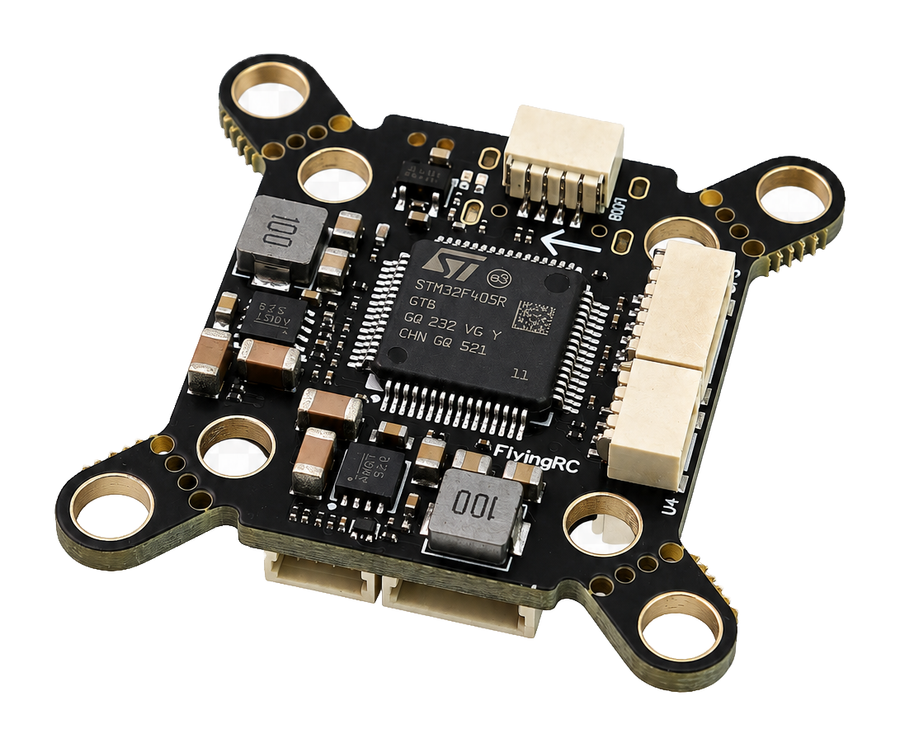
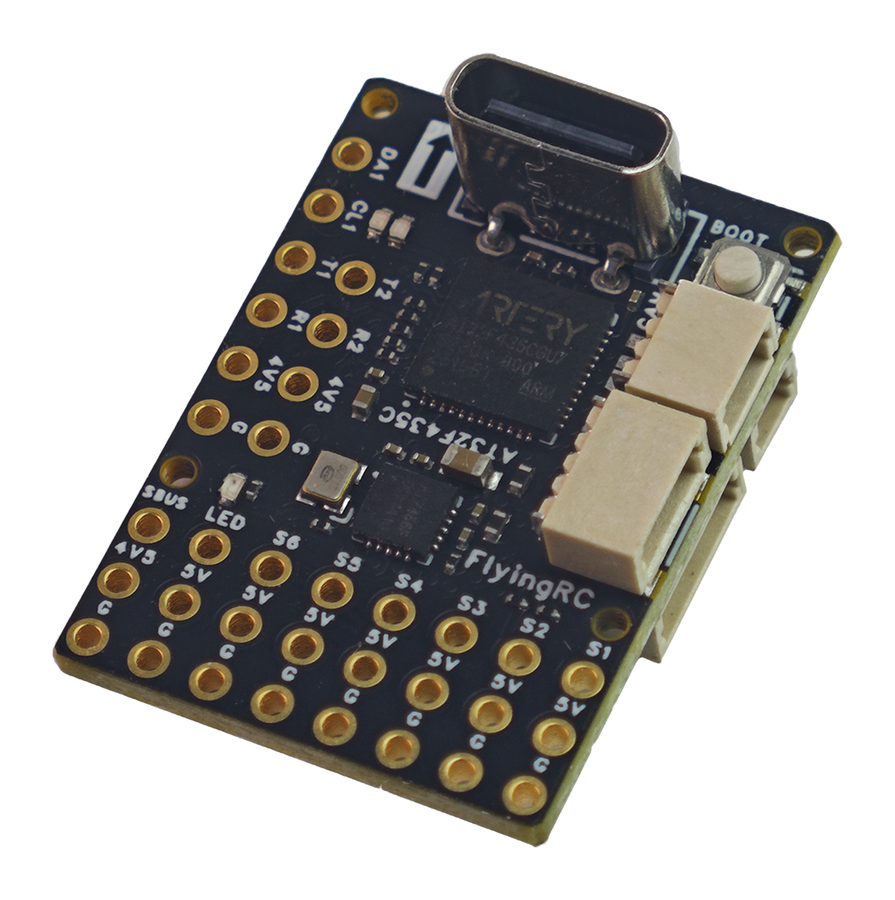
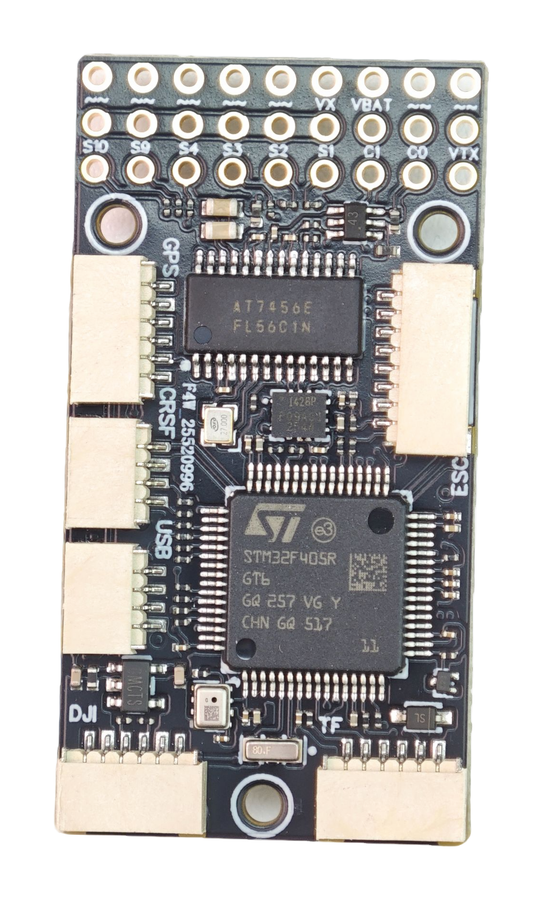
F4Wing Mini MK1 F405 Fixed-Wing Flight Controller

An ultra-small fixed-wing autopilot board. It is the central controller for a small plane: it reads sensors, runs ArduPilot/INAV-style flight firmware, outputs servo/PWM control, and provides connectors for receiver and HD video equipment.

Current store option: BMI270. Earlier ICM versions are discontinued.

Flight Controllers

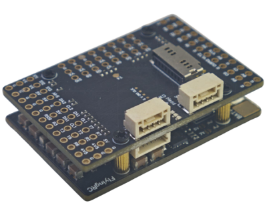
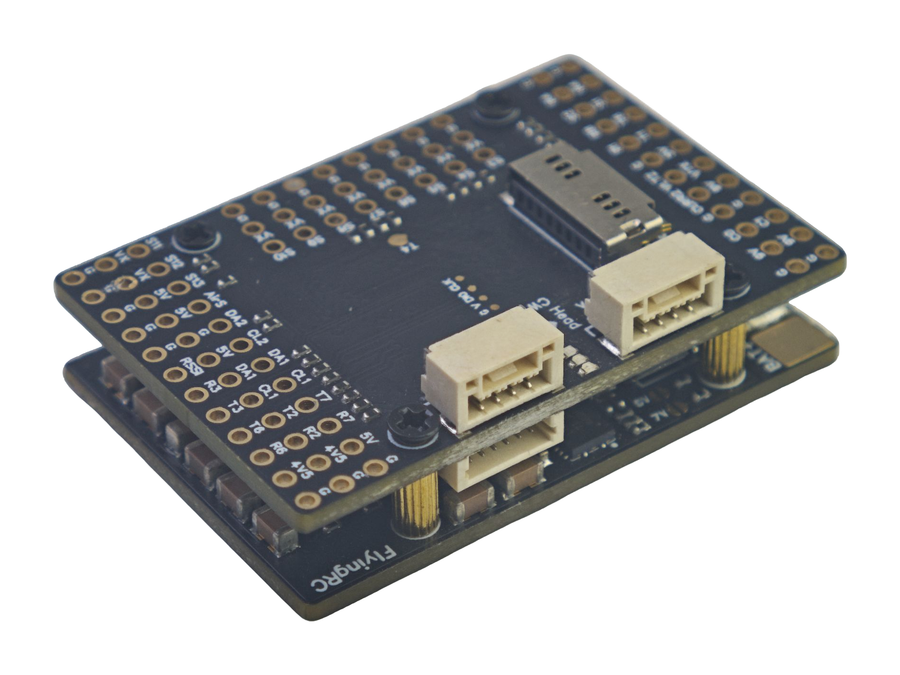
F4WSE F405 Fixed-wing Flight Controller

A fixed-wing F405 autopilot board for ArduPilot/INAV-style airplane builds. It sits between receiver/sensors and aircraft servos/ESC, handling stabilization, navigation, telemetry, and flight-mode control.

Flight Controllers

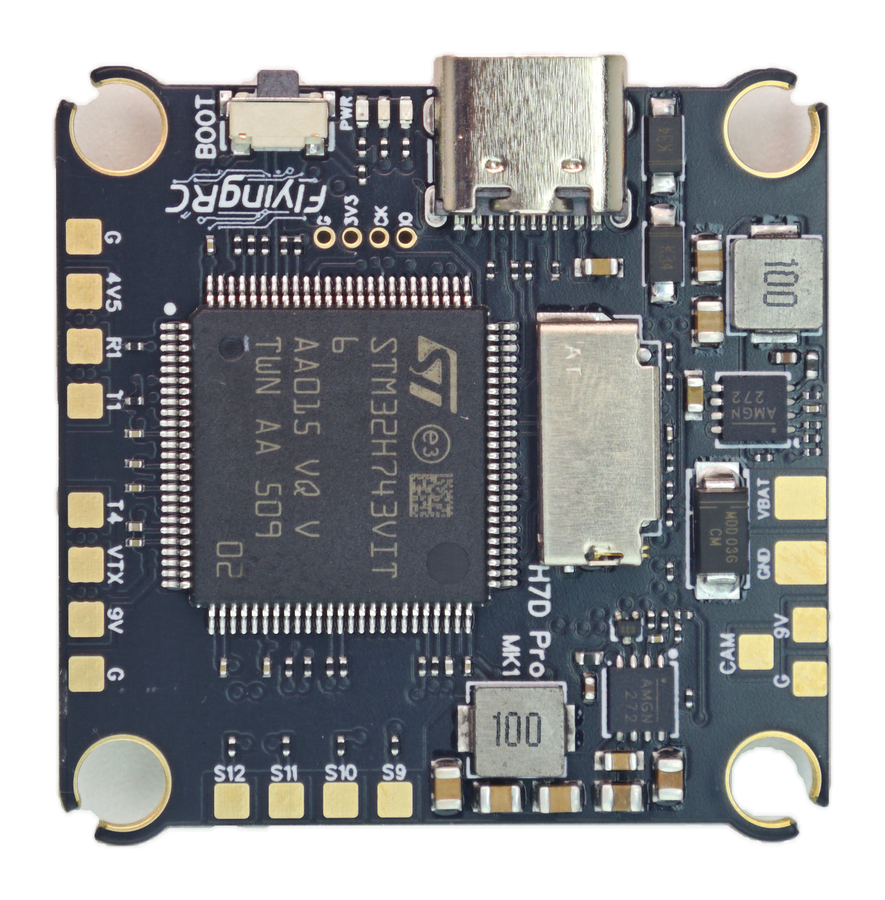
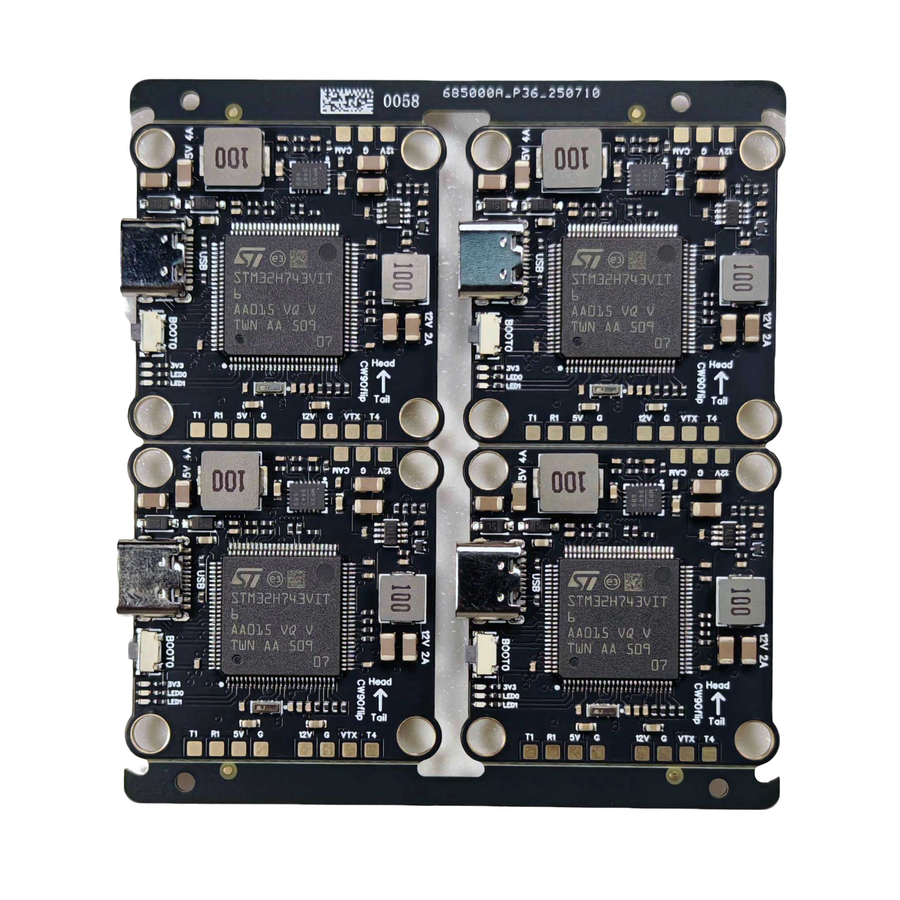
H7D H743 FPV Flight Controller

A high-performance H743 FPV flight controller. It is the main control board for a multirotor: it runs Betaflight/AP/INAV firmware, reads dual gyros and barometer, drives ESC/PWM outputs, and powers/controls VTX and camera accessories.