Sensors and GPS
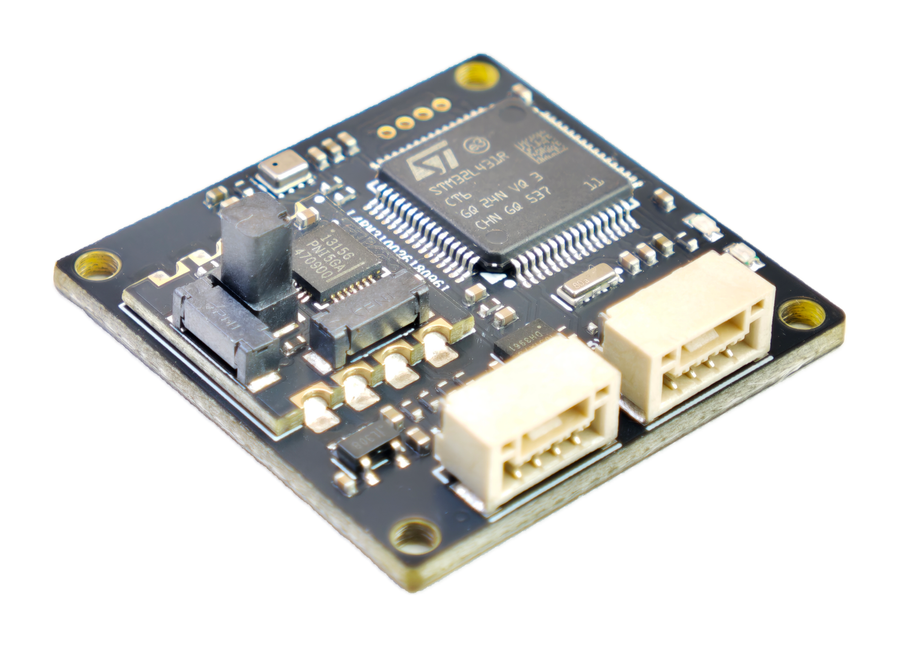
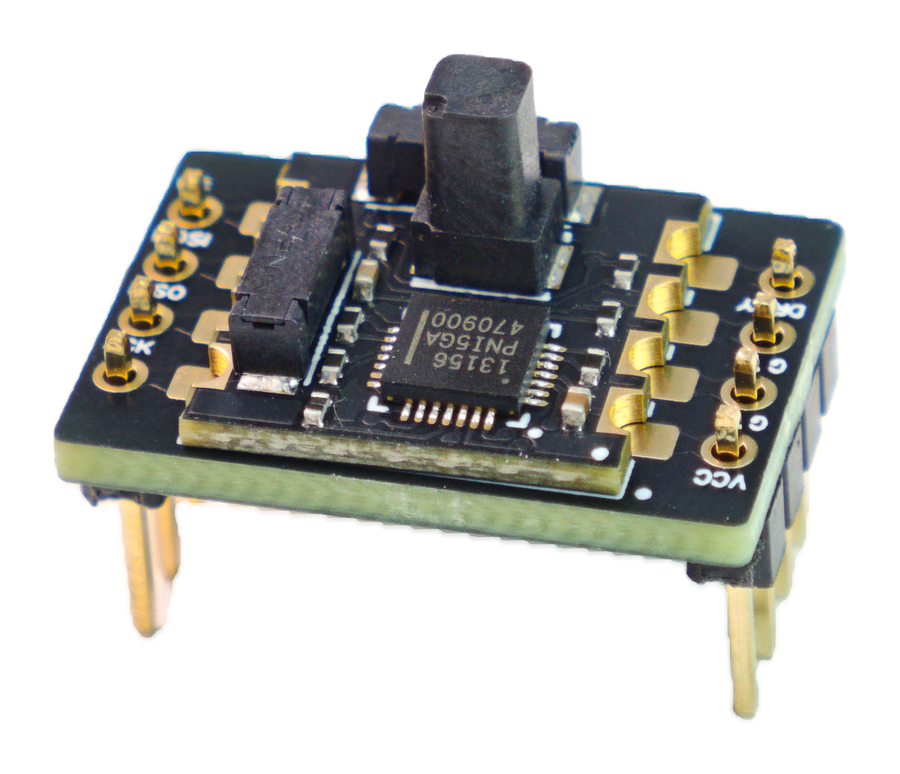
RM3100 SPI Compass Module
A remote-mountable three-axis compass module for heading measurement in aircraft, robotics, and navigation projects.
Match the sensor function and electrical interface to the flight controller and firmware configuration.
UART, I2C, SPI and CAN devices are not interchangeable. Verify the connector pinout, bus voltage, firmware driver and port configuration before installation.
GPS and compass performance depends on placement and electrical noise. Current and airspeed sensors also require the correct measurement path and calibration procedure described by their documentation.
A remote-mountable three-axis compass module for heading measurement in aircraft, robotics, and navigation projects.
A CAN-bus compass module built around the PNI RM3100 geomagnetic sensor and AP_Periph-style firmware. It gives autopilots cleaner heading data when the main flight controller is affected by current, motors, or magnetic interference, while keeping remote communication on a robust CAN link.
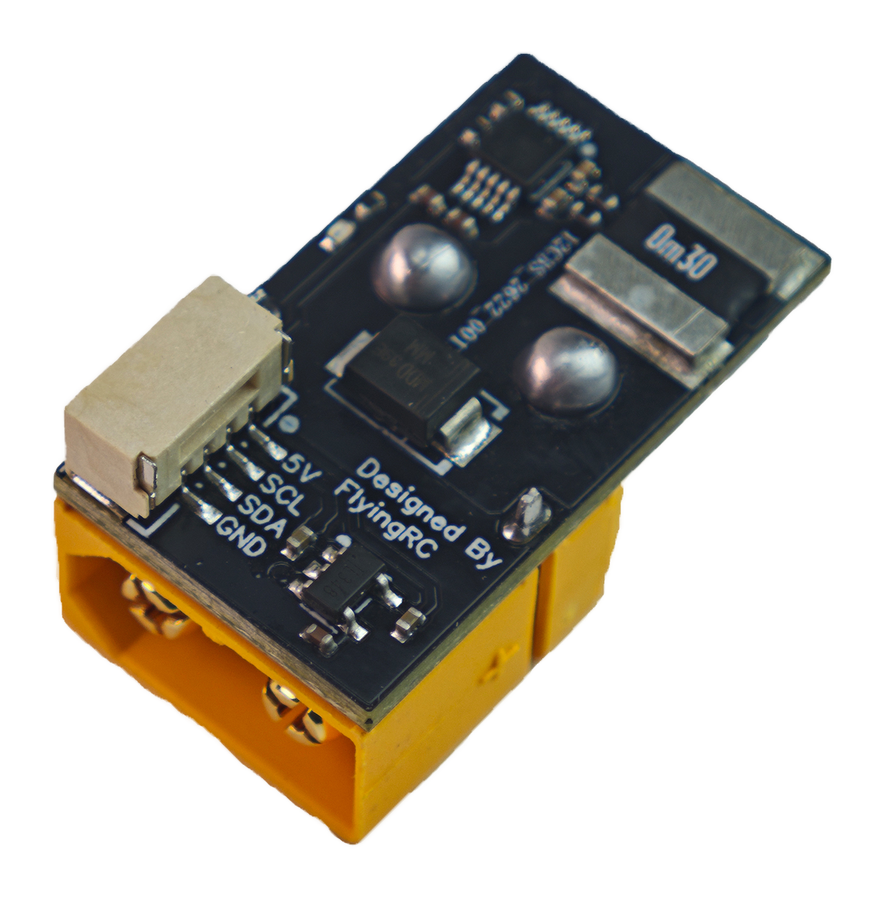
An external I2C current and voltage sensor for flight controllers. It uses an INA226 sensor so ArduPilot/PX4 systems can read battery voltage and current from an external module instead of relying on an onboard analog current sensor.
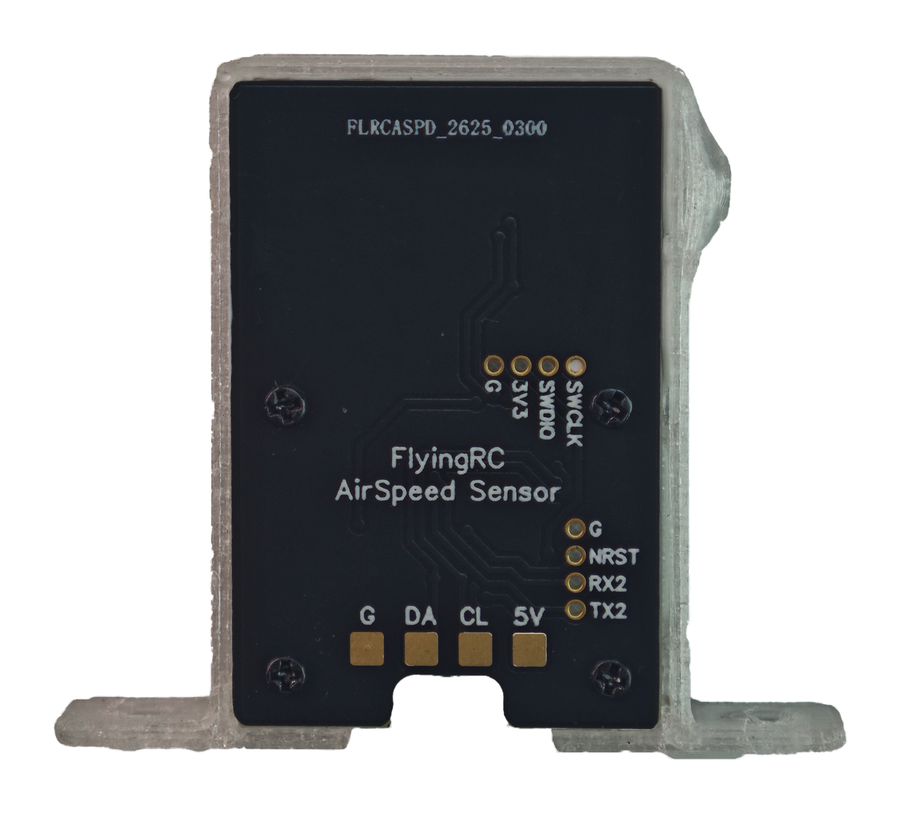
The latest integrated I2C airspeed sensor for fixed-wing aircraft using ArduPilot airspeed workflows.
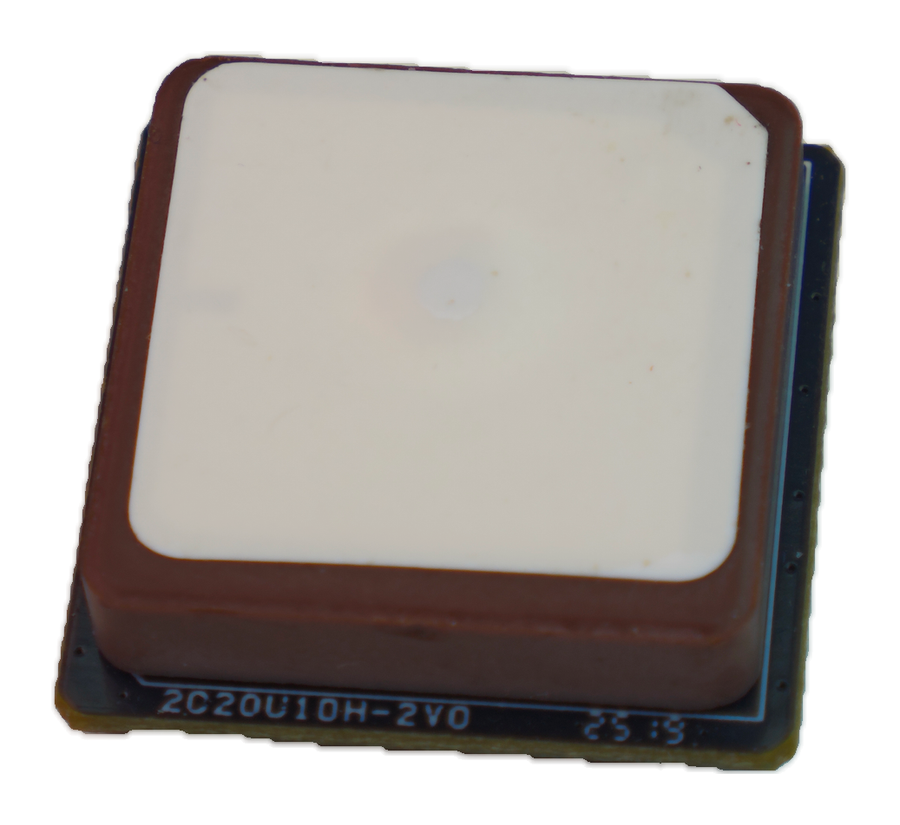
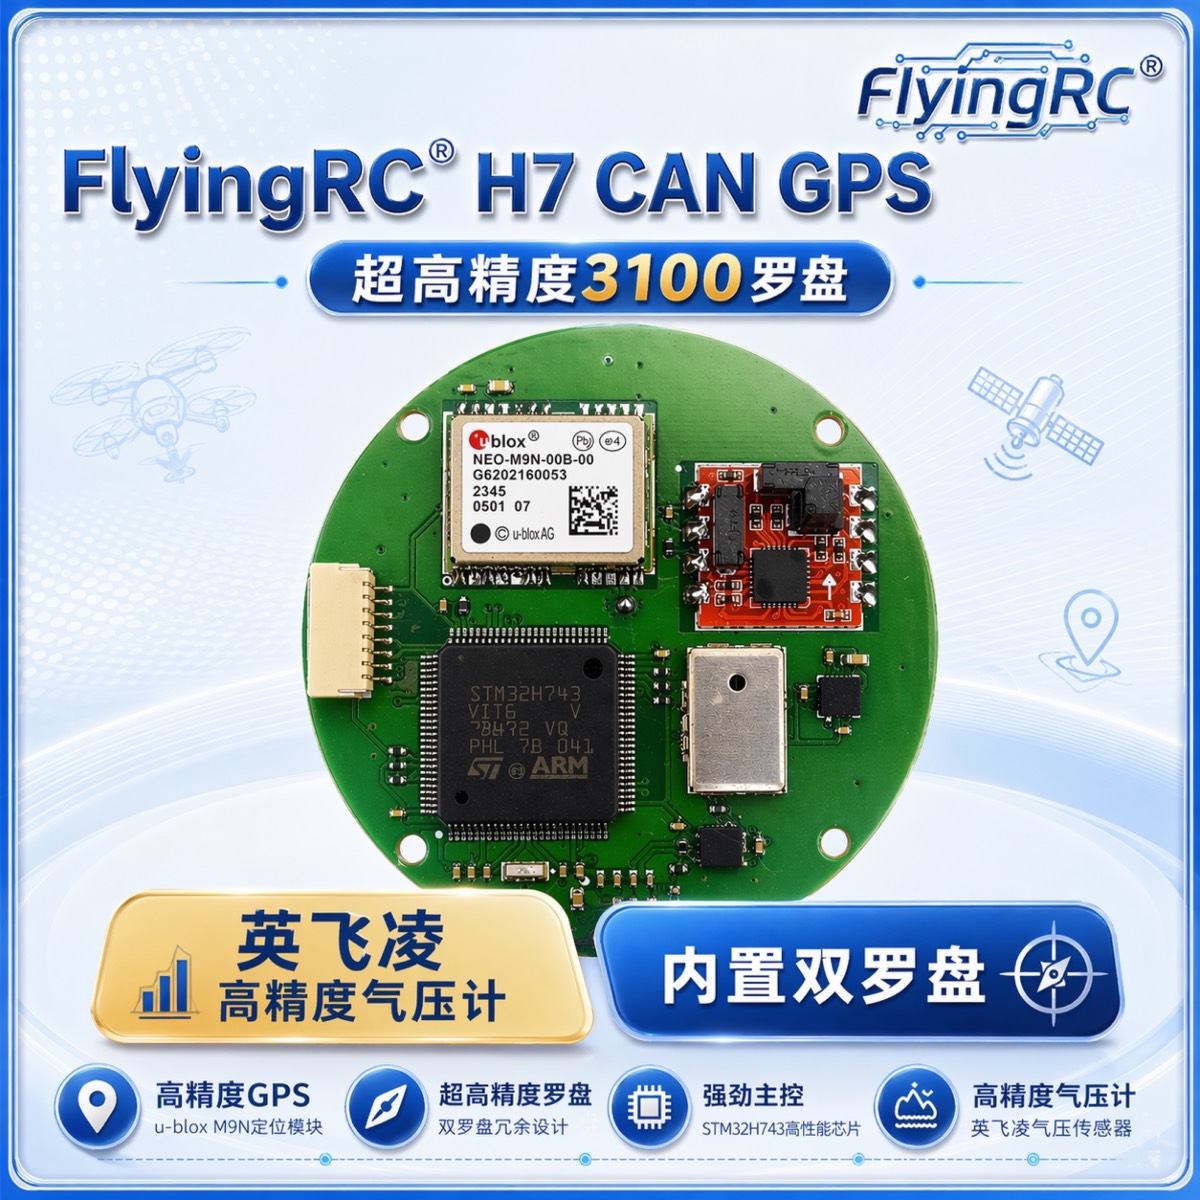
A U-Blox M10 GPS module for providing location data to flight controllers, robots, or navigation systems.
A GPS/navigation accessory page for FlyingRC CAN/GPS-style products. It provides position data to the flight controller so autonomous modes, return-to-home, navigation, and logging can work.